Core team

Meet the team building ZIMA.

Subvision brings together mechanical design, electronics, software, and venture development around one job: building a practical system for prevention-first hull maintenance.

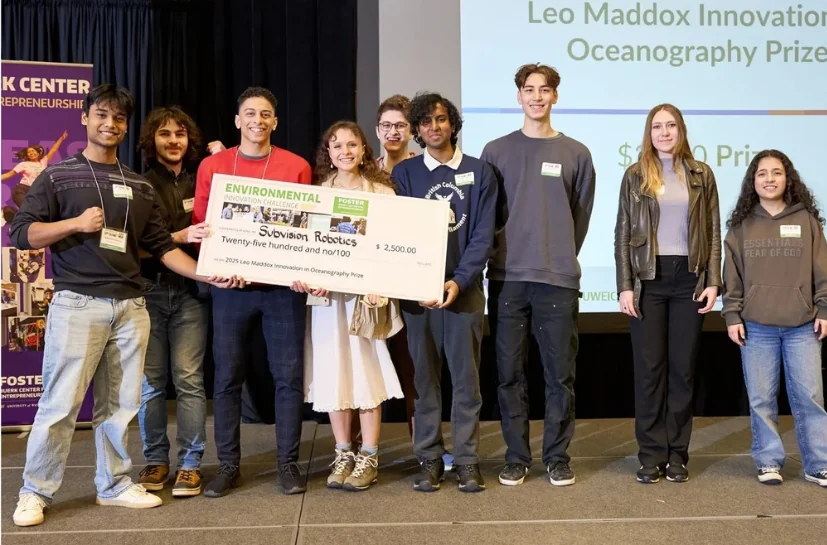
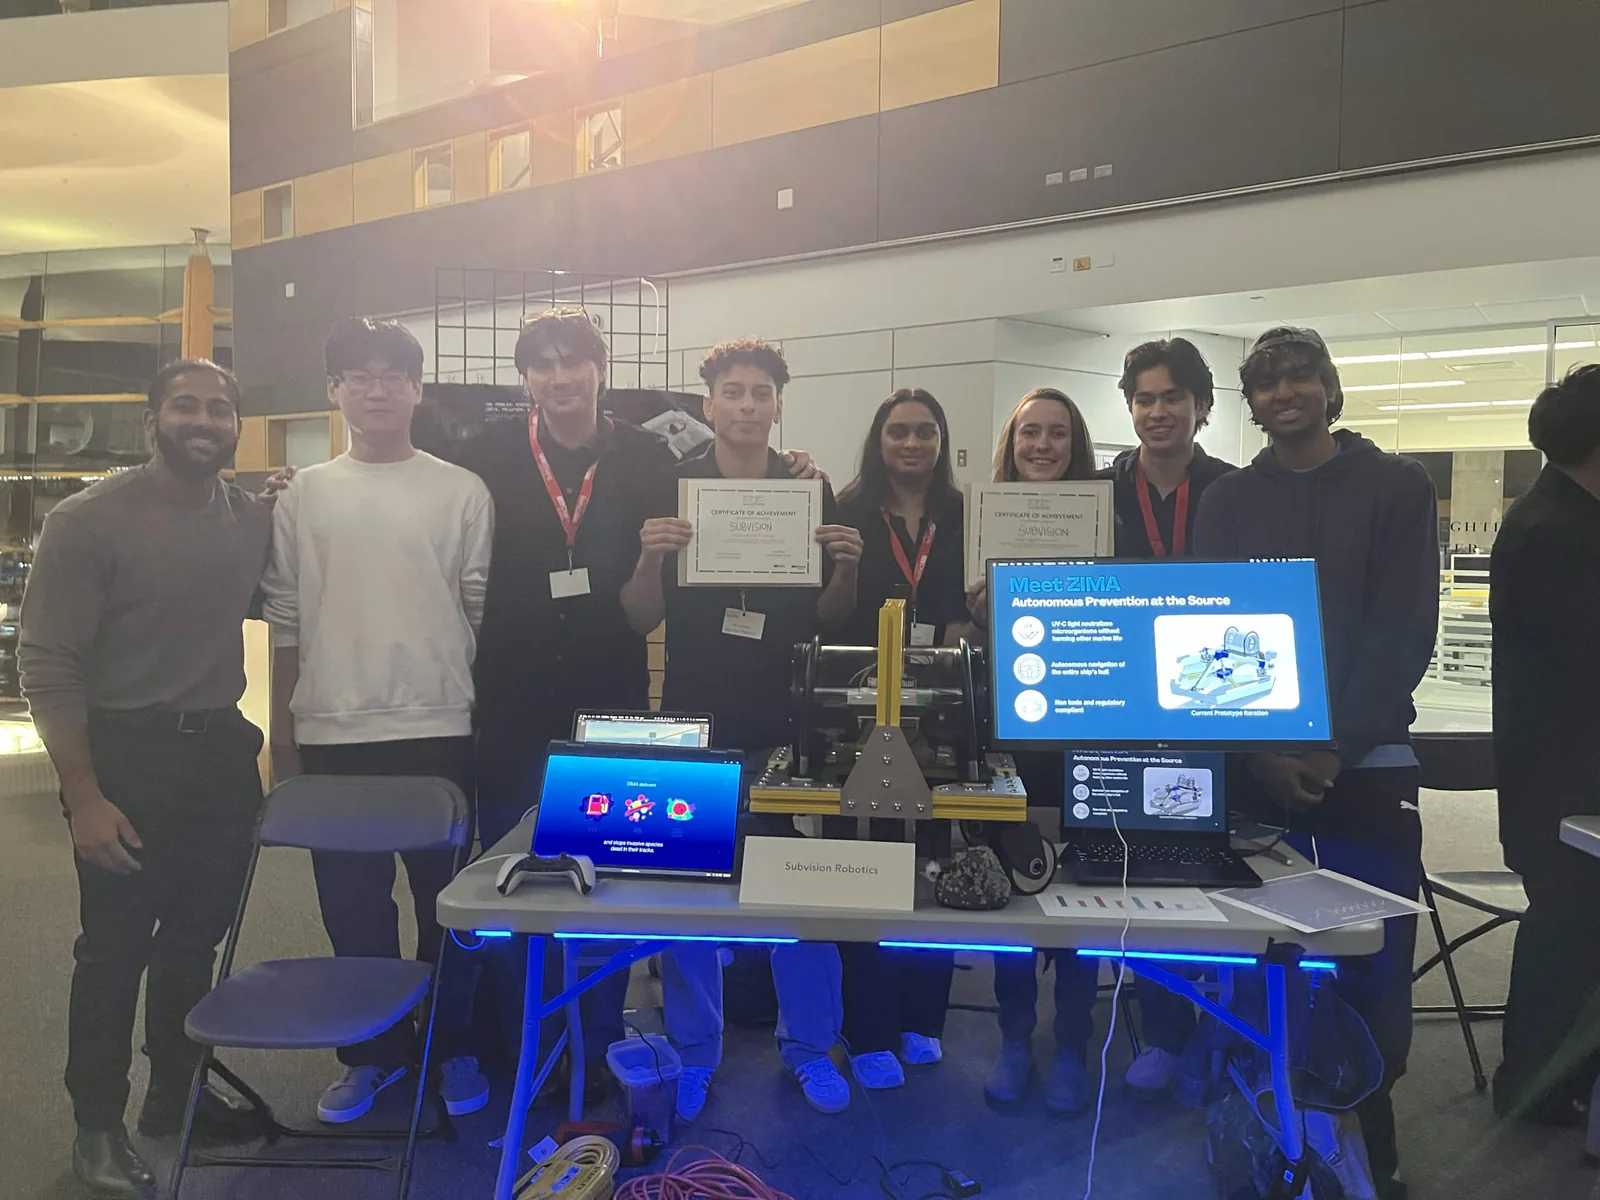
Subvision team at the Maddox Prize presentation

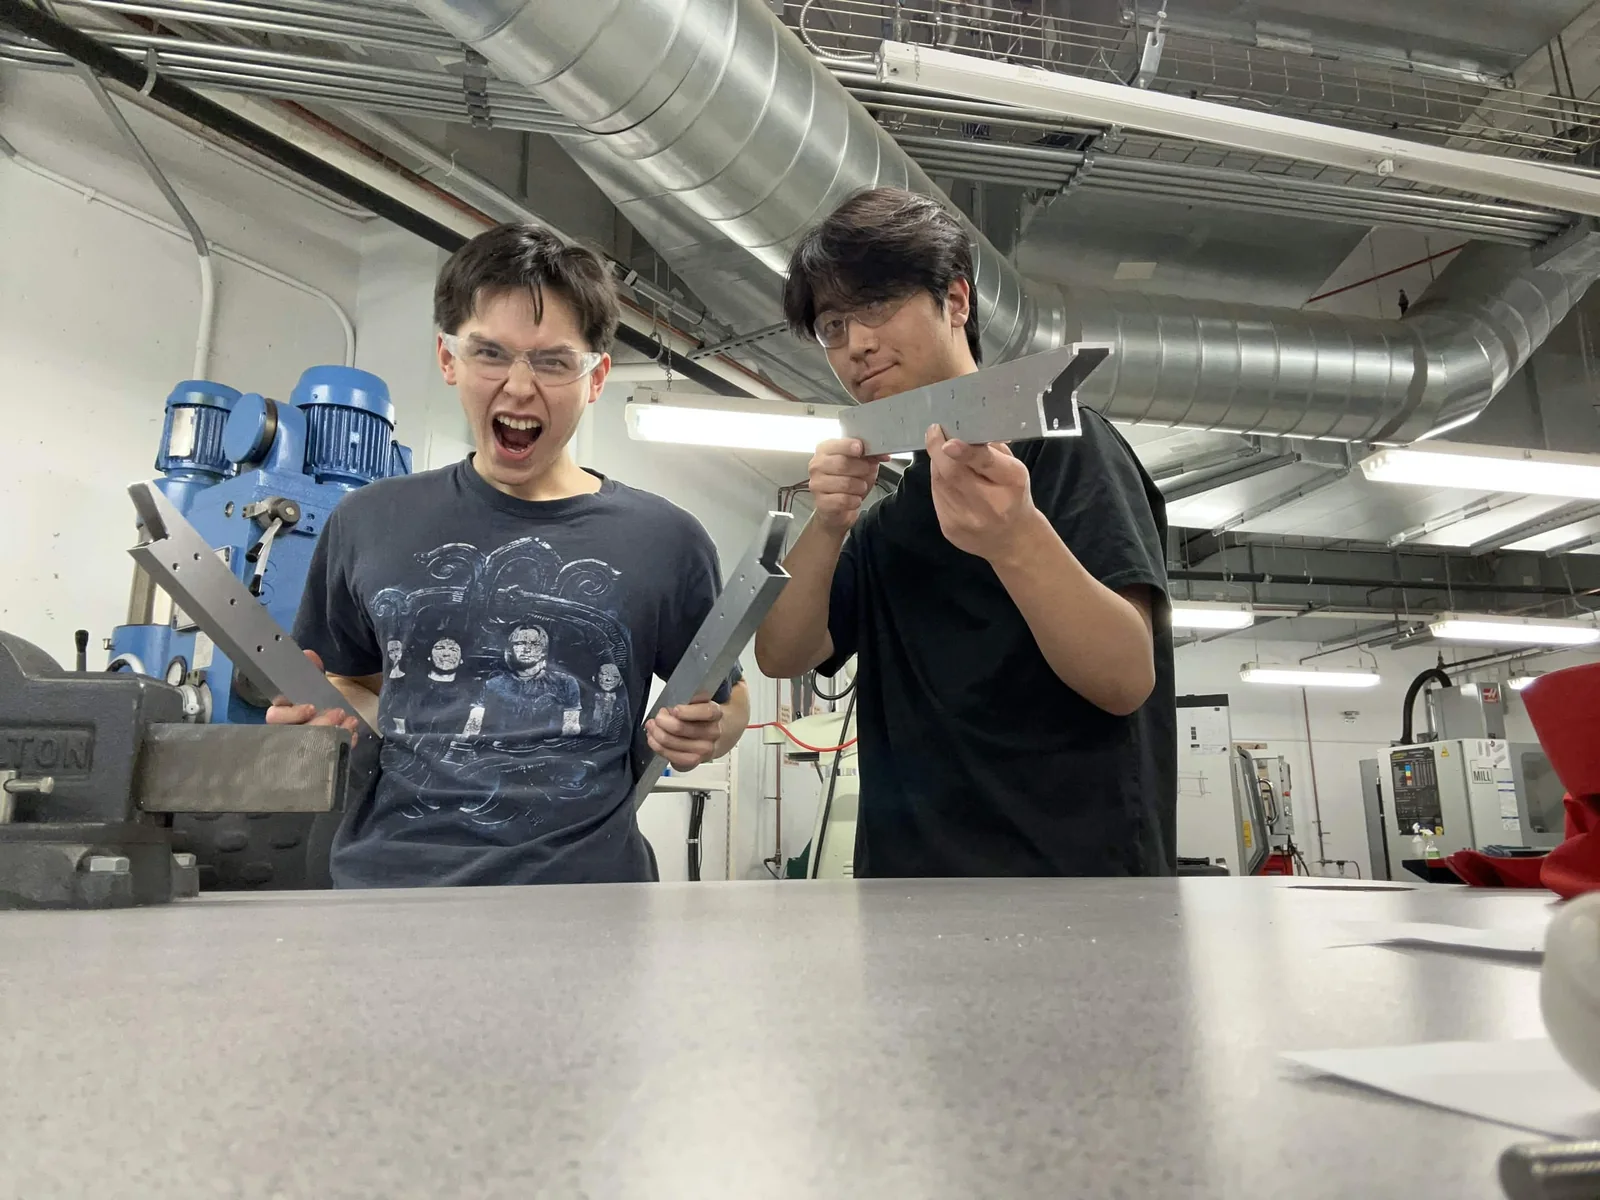
Subvision started with a group of us at Simon Fraser University who wanted to build underwater robots. We created a marine engineering club to make it happen. Building a robot together took us to the MATE ROV World Championship in Tennessee, but it also made us want to do something beyond competitions. We wanted to take what we’d learned and put it toward a problem that mattered to the ocean and the people who work on it.

Today, we’re a Vancouver-based team building ZIMA from the ground up. We bring different strengths in mechanical design, electronics, power systems, and robotics software, but the work is rarely neatly divided. We help each other troubleshoot, challenge each other’s ideas, and learn together when a design doesn’t behave the way we expected. From the custom underwater drive system to the controls that guide ZIMA across a ship’s hull, this is something we’re making together. We’re proud of how far we’ve come, and we’re building toward a goal we all care about: helping ships stay efficient while protecting the waters they travel through.

Leadership board

A small, hands-on team building the system across hardware, software, and business.

Leadership

The same people shaping the product are also designing it, building it, testing it, and explaining it to partners.

Ali Hakam headshot

Ali Hakam

CEO & Technical Lead

Leads product direction, technical execution, and the broader vision behind ZIMA.

Abi Levin headshot

Abi Levin

Mechanical Lead

Leads mechanical design and turns the rover architecture into manufacturable hardware.
Dennis Cofler headshot

Dennis Cofler

Mechanical Lead

Supports mechanical design, prototyping, and subsystem refinement across the platform.
Sehaj Khalsi headshot

Sehaj Khalsi

Mechanical Member

UV-C specialist integrating the electronics.

Onur Yildiz headshot

Onur Yildiz

Electronics Lead

Leads electronics integration and electrical robustness for subsea operation.

Natasia Fisher headshot

Natasia Fisher

Electronics Member

Supports electronics integration and electrical systems development for subsea operation.

Saketh Poori headshot

Saketh Poori

Software Lead

Leads software architecture, autonomy, and controls development.

Hayden Mai headshot

Hayden Mai

Software Lead

Works on applied software and system integration across the rover stack.
How the team works

Hardware and software move forward together.

Subvision gets stronger when every discipline pushes the same system forward. Each build cycle turns CAD into prototypes, prototypes into test data, and test data into the next design decision.

Work with the team

Interested in the mission, the product, or the next phase of testing?

Whether the conversation is about pilots, funding, technical collaboration, or public showcase opportunities, Subvision is open to talking.

Review the technology